Feedback Models and System Response - Control Systems - Electronics & Communication Engineering Previous Year Questions
Practice Feedback Models and System Response - Control Systems - Electronics & Communication Engineering previous year questions organised from real papers, with year-wise coverage and clear topic navigation.
29Papers
19Years
67Questions
1Topics
Feedback Models and System Response question pattern
Every graph below is calculated only from this selection.
Questions by year
Compare question counts across years.
Difficulty distribution
How the classified questions are distributed by difficulty.
67questions
Medium57
85.1%
Easy9
13.4%
Hard1
1.5%
Question type distribution
MCQ, numerical, multiple-select and other formats found in these papers.
67questions
MCQ51
76.1%
Numerical Answer Type (NAT)9
13.4%
MSQ4
6%
Fill in the blanks3
4.5%
Subject weightage
Top subjects by unique question coverage.
Electronics & Communication Engineering
67 Qs
Most asked topics
Top topics across the included previous year papers.
Control Systems
67 Qs
Subtopic coverage
Top subtopics inside this exact selection.
Feedback Models and System Response
67 Qs
Paper coverage
Question coverage for the most populated papers. Every active PYP paper remains listed below.
Electronics and Communication Engineering (EC) 2026
3 Qs
Electronics & Communication Engineering (EC) 2025
2 Qs
Electronics & Communication Engineering (EC) 2024
2 Qs
Electronics & Communication Engineering (EC) 2023
2 Qs
Electronics & Communication Engineering (EC) 2022
2 Qs
Electronics & Communication Engineering (EC) 2021
2 Qs
Electronics & Communication Engineering (EC) 2020
2 Qs
Electronics & Communication Engineering (EC) 2019
2 Qs
Electronics & Communication Engineering (EC) 2018
2 Qs
Electronics & Communication Engineering (EC) 2017
3 Qs
Electronics & Communication Engineering (EC) 2017 [Session 2]
3 Qs
Electronics & Communication Engineering (EC) 2017 [Session 1]
2 Qs
Electronics & Communication Engineering (EC) 2016 [Session 3]
3 Qs
Electronics & Communication Engineering (EC) 2016 [Session 2]
2 Qs
Electronics & Communication Engineering (EC) 2016 [Session 1]
1 Qs
Electronics & Communication Engineering (EC) 2014 [Session 1]
1 Qs
Electronics & Communication Engineering (EC) 2014 [Session 2]
1 Qs
Electronics & Communication Engineering (EC) 2014 [Session 3]
1 Qs
Electronics & Communication Engineering (EC) 2014 [Session 4]
1 Qs
Electronics & Communication Engineering (EC) 2013 [Session 4]
6 Qs
Electronics & Communication Engineering (EC) 2013 [Session 1]
3 Qs
Electronics & Communication Engineering (EC) 2013 [Session 2]
3 Qs
Electronics & Communication Engineering (EC) 2013 [Session 3]
2 Qs
Electronics & Communication Engineering (EC) 2012
1 Qs
Electronics & Communication Engineering (EC) 2011
1 Qs
Electronics & Communication Engineering (EC) 2010
4 Qs
Electronics & Communication Engineering (EC) 2009
2 Qs
Electronics & Communication Engineering (EC) 2008
3 Qs
Electronics & Communication Engineering (EC) 2007
5 Qs
Included previous year papers
Newest papers appear first. Search these papers or sort by year and name.
Paper name
Year
PDF
Attempt
Electronics and Communication Engineering (EC) 20262026
All Feedback Models and System Response previous year questions
Practice every matching question in batches of 20, with every available option.
1
2007 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2007
A control system with a PD controller is shown in the figure. If the velocity error constant \(K_v = 1000\) and the damping ratio \(\zeta = 0.5\), then the values of \(K_p\) and \(K_D\) are
2007 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2007
The state space representation of a separately excited DC servo motor dynamics is given as \[ \begin{bmatrix} \frac{d\omega}{dt} \\ \frac{di_a}{dt} \end{bmatrix} = \begin{bmatrix} -1 & 1 \\ -1 & -10 \end{bmatrix} \begin{bmatrix} \omega \\ i_a \end{bmatrix} + \begin{bmatrix} 0 \\ 10 \end{bmatrix} u \] where \(\omega\) is the speed of the motor, \(i_a\) is the armature current and \(u\) is the armature voltage. The transfer function \(\frac{\omega(s)}{U(s)}\) of the motor is
2008 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2008
Step responses of a set of three second-order underdamped systems all have the same percentage overshoot. Which of the following diagrams represents the poles of the three systems?
2008 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2008
Group I lists a set of four transfer functions. Group II gives a list of possible step responses y(t). Match the step responses with the corresponding transfer functions.
2008 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2008
The magnitude of frequency response of an underdamped second order system is 5 at 0 rad/sec and peaks to \[\frac{10}{\sqrt{3}}\] at \(5\sqrt{2}\) rad/sec. The transfer function of the system is
2009 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2009
Consider the system \(\frac{dx}{dt} = Ax + Bu\) with \(A = \begin{bmatrix} 1 & 0 \\ 0 & 1 \end{bmatrix}\) and \(B = \begin{bmatrix} p \\ q \end{bmatrix}\) where \(p\) and \(q\) are arbitrary real numbers. Which of the following statements about the controllability of the system is true ?
2010 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2010
A unity negative feedback closed loop system has a plant with the transfer function \(G(s) = \frac{1}{s^2 + 2s + 2}\) and a controller Gc(s) in the feedforward path. For a unit step input, the transfer function of the controller that gives minimum steady state error is
2011 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2011
The block diagram of a system with one input \(u\) and two outputs \(y_1\) and \(y_2\) is given below.
A state space model of the above system in terms of the state vector \(\underline{x}\) and the output vector \(\underline{y} = [y_1 \quad y_2]^T\) is
2012 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2012
The state variable description of an LTI system is given by \( \begin{pmatrix} \dot{x}_1 \\ \dot{x}_2 \\ \dot{x}_3 \end{pmatrix} = \begin{pmatrix} 0 & a_1 & 0 \\ 0 & 0 & a_2 \\ a_3 & 0 & 0 \end{pmatrix} \begin{pmatrix} x_1 \\ x_2 \\ x_3 \end{pmatrix} + \begin{pmatrix} 0 \\ 0 \\ 1 \end{pmatrix} u \) \( y = \begin{pmatrix} 1 & 0 & 0 \end{pmatrix} \begin{pmatrix} x_1 \\ x_2 \\ x_3 \end{pmatrix} \) where y is the output and u is the input. The system is controllable for
2013 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2013 [Session 1]
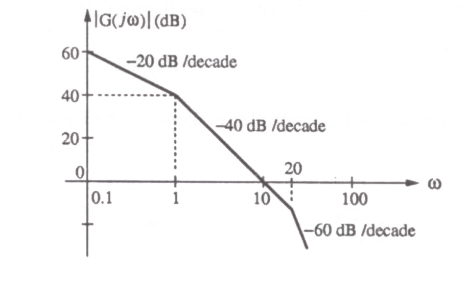
The Bode plot of a transfer function \( G(s) \) is shown in the figure below. The gain \( 20\log|G(s)| \) is 32 dB and −8 dB at 1 rad/s and 10 rad/s respectively. The phase is negative for all ω. Then \( G(s) \) is
2013 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2013 [Session 1]
The open-loop transfer function of a dc motor is given as \( \frac{\omega(s)}{V_a(s)} = \frac{10}{1+10s} \). When connected in feedback as shown below, the approximate value of \( K_a \) that will reduce the time constant of the closed loop system by one hundred times as compared to that of the open-loop system is
2013 · Electronics & Communication Engineering · Control Systems · Feedback Models and System Response
Electronics & Communication Engineering (EC) 2013 [Session 2]
The Bode plot of a transfer function $G(s)$ is shown in the figure below.
The gain ($20 \log|G(s)|$) is 32 dB and –8 dB at 1 rad/s and 10 rad/s respectively. The phase is negative for all $\omega$. Then $G(s)$ is