My Cart
Your Cart 0

    Your cart is empty.

  • Total (Amount) ₹0.00
Previous year question hub

Feedback Modelling and System Response - Control Systems - Instrumentation Engineering Previous Year Questions

Practice Feedback Modelling and System Response - Control Systems - Instrumentation Engineering previous year questions organised from real papers, with year-wise coverage and clear topic navigation.

21Papers
18Years
76Questions
1Topics

Feedback Modelling and System Response question pattern

Every graph below is calculated only from this selection.

Questions by year

Compare question counts across years.

Difficulty distribution

How the classified questions are distributed by difficulty.

Medium 47 61.8%
Easy 25 32.9%
Hard 4 5.3%
Question type distribution

MCQ, numerical, multiple-select and other formats found in these papers.

MCQ 62 81.6%
Numerical Answer Type (NAT) 10 13.2%
MSQ 3 3.9%
Fill in the blanks 1 1.3%

Subject weightage

Top subjects by unique question coverage.

Instrumentation Engineering
76 Qs

Most asked topics

Top topics across the included previous year papers.

Control Systems
76 Qs

Subtopic coverage

Top subtopics inside this exact selection.

Feedback Modelling and System Response
76 Qs

Paper coverage

Question coverage for the most populated papers. Every active PYP paper remains listed below.

Instrumentation Engineering (IN) 2026
4 Qs
Instrumentation Engineering (IN) 2025
2 Qs
Instrumentation Engineering (IN) 2024
5 Qs
Instrumentation Engineering (IN) 2023
1 Qs
Instrumentation Engineering (IN) 2022
4 Qs
Instrumentation Engineering (IN) 2021
1 Qs
Instrumentation Engineering (IN) 2020
4 Qs
Instrumentation Engineering (IN) 2019
6 Qs
Instrumentation Engineering (IN) 2018
1 Qs
Instrumentation Engineering (IN) 2017
3 Qs
Instrumentation Engineering (IN) 2016
3 Qs
Instrumentation Engineering (IN) 2014
2 Qs
Instrumentation Engineering (IN) 2013 [Session 3]
6 Qs
Instrumentation Engineering (IN) 2013 [Session 1]
5 Qs
Instrumentation Engineering (IN) 2013 [Session 2]
5 Qs
Instrumentation Engineering (IN) 2013 [Session 4]
5 Qs
Instrumentation Engineering (IN) 2011
4 Qs
Instrumentation Engineering (IN) 2010
2 Qs
Instrumentation Engineering (IN) 2009
4 Qs
Instrumentation Engineering (IN) 2008
4 Qs
Instrumentation Engineering (IN) 2007
5 Qs

Included previous year papers

Newest papers appear first. Search these papers or sort by year and name.

Paper nameYearPDFAttempt
Instrumentation Engineering (IN) 20262026
4 questions in this view
2026
Instrumentation Engineering (IN) 20252025
2 questions in this view
2025
Instrumentation Engineering (IN) 20242024
5 questions in this view
2024
Instrumentation Engineering (IN) 20232023
1 questions in this view
2023
Instrumentation Engineering (IN) 20222022
4 questions in this view
2022
Instrumentation Engineering (IN) 20212021
1 questions in this view
2021
Instrumentation Engineering (IN) 20202020
4 questions in this view
2020
Instrumentation Engineering (IN) 20192019
6 questions in this view
2019
Instrumentation Engineering (IN) 20182018
1 questions in this view
2018
Instrumentation Engineering (IN) 20172017
3 questions in this view
2017
Instrumentation Engineering (IN) 20162016
3 questions in this view
2016
Instrumentation Engineering (IN) 20142014
2 questions in this view
2014
Instrumentation Engineering (IN) 2013 [Session 1]2013
5 questions in this view
2013
Instrumentation Engineering (IN) 2013 [Session 2]2013
5 questions in this view
2013
Instrumentation Engineering (IN) 2013 [Session 3]2013
6 questions in this view
2013
Instrumentation Engineering (IN) 2013 [Session 4]2013
5 questions in this view
2013
Instrumentation Engineering (IN) 20112011
4 questions in this view
2011
Instrumentation Engineering (IN) 20102010
2 questions in this view
2010
Instrumentation Engineering (IN) 20092009
4 questions in this view
2009
Instrumentation Engineering (IN) 20082008
4 questions in this view
2008
Instrumentation Engineering (IN) 20072007
5 questions in this view
2007

All Feedback Modelling and System Response previous year questions

Practice every matching question in batches of 20, with every available option.

1
2009 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2009
A plant with a transfer function \(\frac{2}{s(s+3)}\) is controlled by a PI controller with \(K_p =1\) and \(K_i \geq 0\) in a unity feedback configuration. The lowest value of \(K_i\) that ensures zero steady state error for a step change in the reference input is
Open complete paper
2
2009 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2009
A linear time-invariant single-input single-output system has a state space model given by \(\frac{dx}{dt} = \mathbf{F}x + \mathbf{G}u\) and \(y = \mathbf{H}x\), where \(\mathbf{F} = \begin{bmatrix} 0 & 1 \\ -4 & -2 \end{bmatrix}\), \(\mathbf{G} = \begin{bmatrix} 0 \\ 1 \end{bmatrix}\), \(\mathbf{H} = [1 \ 0]\). Here \(x\) is the state vector, \(u\) is the input, and \(y\) is the output. The damping ratio of the system is
Open complete paper
3
2009 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2009
If the disturbance is measurable, its effect on the output can be minimized significantly using a feedforward controller \(G_{ff}(s)\). To eliminate the component of the output due to \(d(t) = \sin t\), \(G_{ff}(j\omega)|_{\omega=1}\) should be

Question diagram

Open complete paper
4
2009 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2009
Let \(G_{ff}(s)\) be a PD controller. If \(d(t) = \sin 2t\), the amplitude of the frequency component of \(y(t)\) due to \(d(t)\) is
Open complete paper
5
2010 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2010

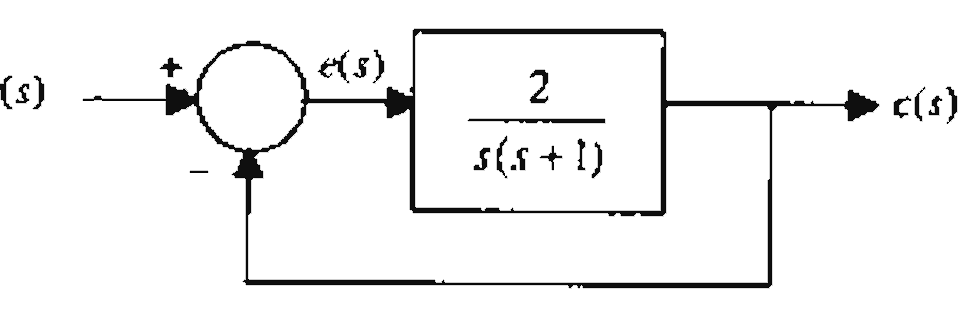
A unit ramp input is applied to the system shown in the adjoining figure. The steady state error in its output is

Open complete paper
6
2010 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2010
A unity feedback system has an open loop transfer function \(G(s) = \frac{k}{s(s+3)}\). The value of k that yields a damping ratio of 0.5 for the closed loop system is
Open complete paper
7
2011 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2011

The signal flow graph of a system is given below. The transfer function (C/R) of the system is
Open complete paper
8
2011 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2011
The characteristics of a thermometer measuring ambient temperature is \(2 \frac{d T_i}{d t} + T_i - T_o = 0\), where \(T_i\) and \(T_o\) are the indicated and ambient temperatures, respectively, both in °C, and time is in seconds. The −3 dB cut-off frequency in the frequency response of the thermometer is

Question diagram

Open complete paper
9
2011 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2011
The unit-step response of a negative unity feedback system with the open-loop transfer function \(G(s) = \frac{6}{s+5}\) is
Open complete paper
10
2011 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2011
The transfer function of the system described by the state-space equations \(\begin{bmatrix} \dot{x_1} \\ \dot{x_2} \end{bmatrix} = \begin{bmatrix} -4 & -1 \\ -3 & -1 \end{bmatrix} \begin{bmatrix} x_1 \\ x_2 \end{bmatrix} + \begin{bmatrix} 1 \\ 1 \end{bmatrix} u, \quad y = \begin{bmatrix} 1 & 0 \end{bmatrix} \begin{bmatrix} x_1 \\ x_2 \end{bmatrix}\) is
Open complete paper
11
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 1]

If the A-matrix of the state space model of a SISO linear time invariant system is rank deficient, the transfer function of the system must have

Open complete paper
12
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 1]
The open-loop transfer function of a dc motor is given as \(\frac{\omega(s)}{V_a(s)} = \frac{10}{1 + 10s}\). When connected in feedback as shown below, the approximate value of \(K_a\) that will reduce the time constant of the closed loop system by one hundred times as compared to that of the open-loop system is
Open complete paper
13
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 1]
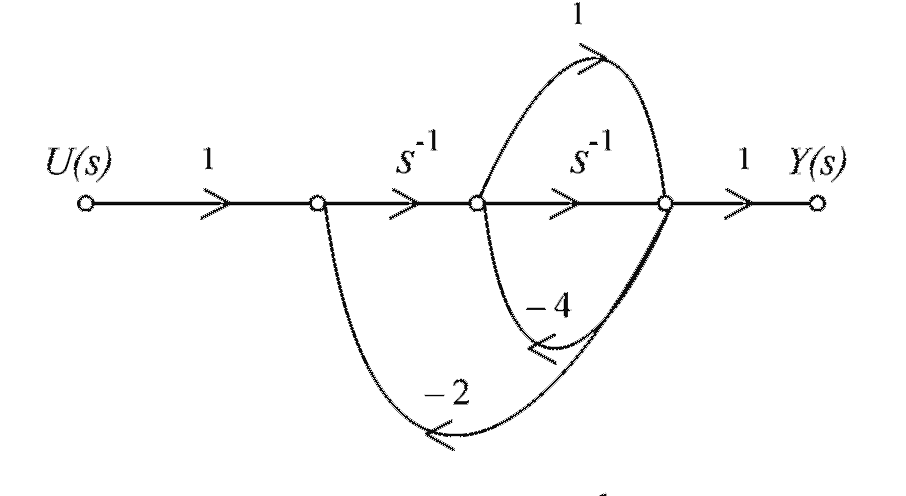
The signal flow graph for a system is given below. The transfer function \(\frac{Y(s)}{U(s)}\) for this system is given as
Open complete paper
14
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 1]
In the circuit shown below the op-amps are ideal. Then \(V_{out}\) in Volts is
Open complete paper
15
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 1]
The gain of the transfer function between the plant output and an additive load disturbance input of frequency 2π/Tu in closed loop with a P-controller designed according to the Ziegler-Nichols tuning rule as given above is
Open complete paper
16
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 2]
The Bode plot of a transfer function \( G(s) \) is shown in the figure below.
The gain \( 20 \log|G(j\omega)| \) is 32 dB and -8 dB at 1 rad/s and 10 rad/s respectively. The phase is negative for all \( \omega \). Then \( G(s) \) is
Open complete paper
17
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 2]
If the \( A \)-matrix of the state space model of a SISO linear time invariant system is rank deficient, the transfer function of the system must have
Open complete paper
18
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 2]
The signal flow graph for a system is given below. The transfer function \( \frac{Y(s)}{U(s)} \) for this system is given as
Open complete paper
19
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 2]
The open-loop transfer function of a dc motor is given as \( \frac{\omega(s)}{V_a(s)} = \frac{10}{1+10s} \). When connected in feedback as shown below, the approximate value of \( K_a \) that will reduce the time constant of the closed loop system by one hundred times as compared to that of the open-loop system is
Open complete paper
20
2013 · Instrumentation Engineering · Control Systems · Feedback Modelling and System Response
Instrumentation Engineering (IN) 2013 [Session 2]
The gain of the transfer function between the plant output and an additive load disturbance input of frequency 2π/Tu , in closed loop with a P-controller designed according to the Ziegler-Nichols tuning rule as given above is
Open complete paper

Showing 20 of 70 questions